Go1
At a glance
The Unitree Go1, the smaller of our two robot dogs: startup video, static transforms for the old dog hardware, and the manual.
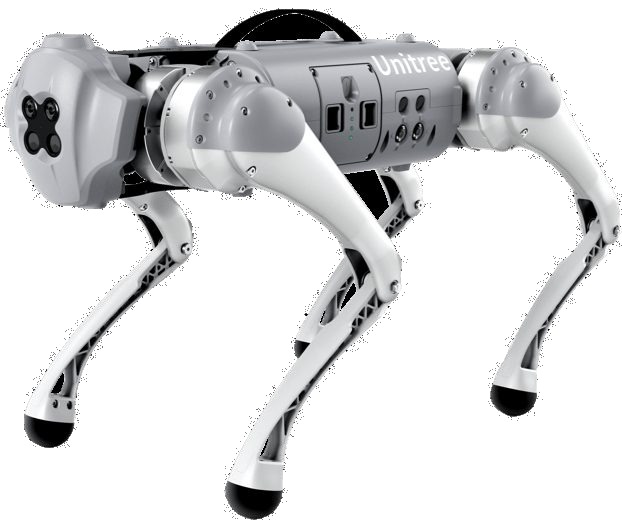
The Go1, the smaller of the two Unitree robots (Unitree product image).
Brandon, This Page Needs Your Help
Brandon Fallin, please review this page. The Dog ROS2 Startup Instructions section is empty, and two of the three Go1s have no name or location yet. Please also tell us which Go1 is Dog 166 (if it exists), and mark which Go1s are ready to use.
Set Up the RTK Ground Station First
This robot uses RTK corrections from the ground station. Before you do anything else, set up the RTK ground station.
The Go1 is the smaller of our two sizes of robot dog.
Ground Robots Need the New ground_docker
Ground robots are set up with ground_docker. Dog 166 (if it exists) is set up perfectly and is the template for the other robots. All the others need to be set up with the new ground_docker.
Our Go1s
We have three Go1s.
| Go1 | Ready to Use | Location | Last Updated |
|---|---|---|---|
| Scooby | Unknown | Autonomy Park | 2026-11-06 |
| Name: Unknown | Unknown | Indoor Lab | 2026-11-06 |
| Name: Unknown | Unknown | Unknown | 2026-11-06 |
Quadruped Startup
Dog ROS2 Startup Instructions
Coming soon
Static Transforms
Brandon, Please Check This Section
Brandon Fallin, please confirm that these static transforms are still relevant.
For the old dog hardware, use the following static transforms in minimal_startup_ground/launch/transforms.launch.py
("unitree", "go1"): {
    "gps": {
        "xyz": (
            0.0643814362384293,
            0.0592539620078344,
            0.152324955289927,
        ),
        "rpy": (0.0, 0.0, 0.0),
    },
    "imu": {
        "xyz": (
            0.246544261742116,
            0.000833506556606053,
            0.160178601155877,
        ),
        "rpy": (
            0.0,
            3.141592653589793,
            0.0,
        ),
    },
    "lidar": {
        "xyz": (
            0.212636626493108,
            0.00104806745515145,
            0.116780107191393,
        ),
        "rpy": (0.0, 0.0, 0.0),
    },
    "zed": {
        "xyz": (
            0.204953137519962,
            0.0010480674551517,
            0.173346896330377,
        ),
        "rpy": (
            0.0,
            0.2617993877991494,
            0.0,
        ),
    },
},